Scene Memory for Robots: Mapping What They See, Reasoning About What Changed – Neo4j @ WAD2026
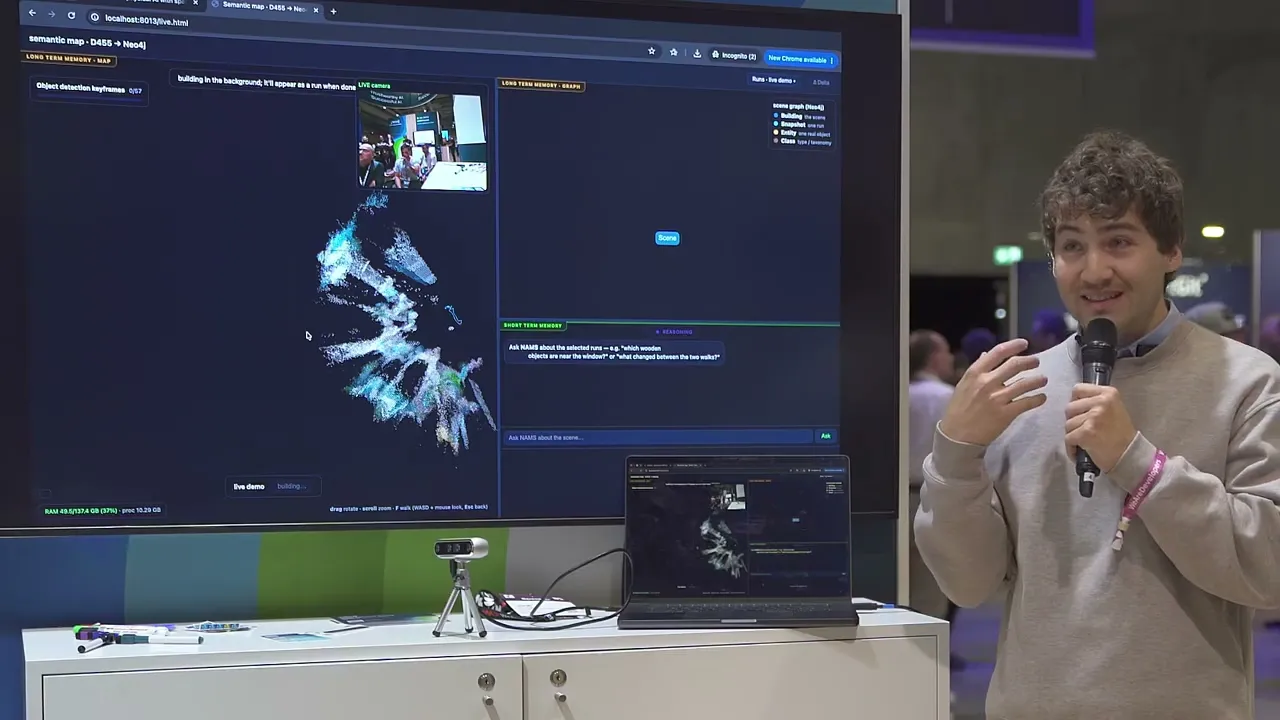 Play video on YouTube: Scene Memory for Robots: Mapping What They See, Reasoning About What Changed – Neo4j @ WAD2026
Up next

From Apple Health to Aura Agent: Building a Personal Longevity Coach in Neo4j – Neo4j @ WAD2026


A live demo of robot memory on Neo4j. As the robot walks, it builds a versioned scene graph of what it sees, so an AI agent can answer questions like 'what changed since last time?' in plain language: the core question behind autonomous inspection and maintenance.
Speaker: Jordi Spranger, Independent AI and Robotic Engineer
@_wearedevs
GenAI & GraphRAG
- Watched Duration: 47:56

- Watched Duration: 20:47

- Watched Duration: 20:46
- Watched Duration: 6:13

- Watched Duration: 14:59

- Watched Duration: 44:31

- Watched Duration: 30:00